Can a Unitree Go2 EDU sensor payload run on the Jetson Orin NX you already have?
Updated 2026-10-29 · YUANZHI ROBOTICS engineering team
Many Go2 EDU owners already have a Jetson Orin NX 16GB on the robot running Ubuntu and ROS 2, and ask whether a sensor payload has to come with its own computer. In most cases it does not. The sensors in a typical inspection payload connect over Ethernet, USB and serial, and each has a ROS 2 driver that runs on a Jetson. What decides the answer is not the software but four practical checks: ports, power, network addresses and spare compute.
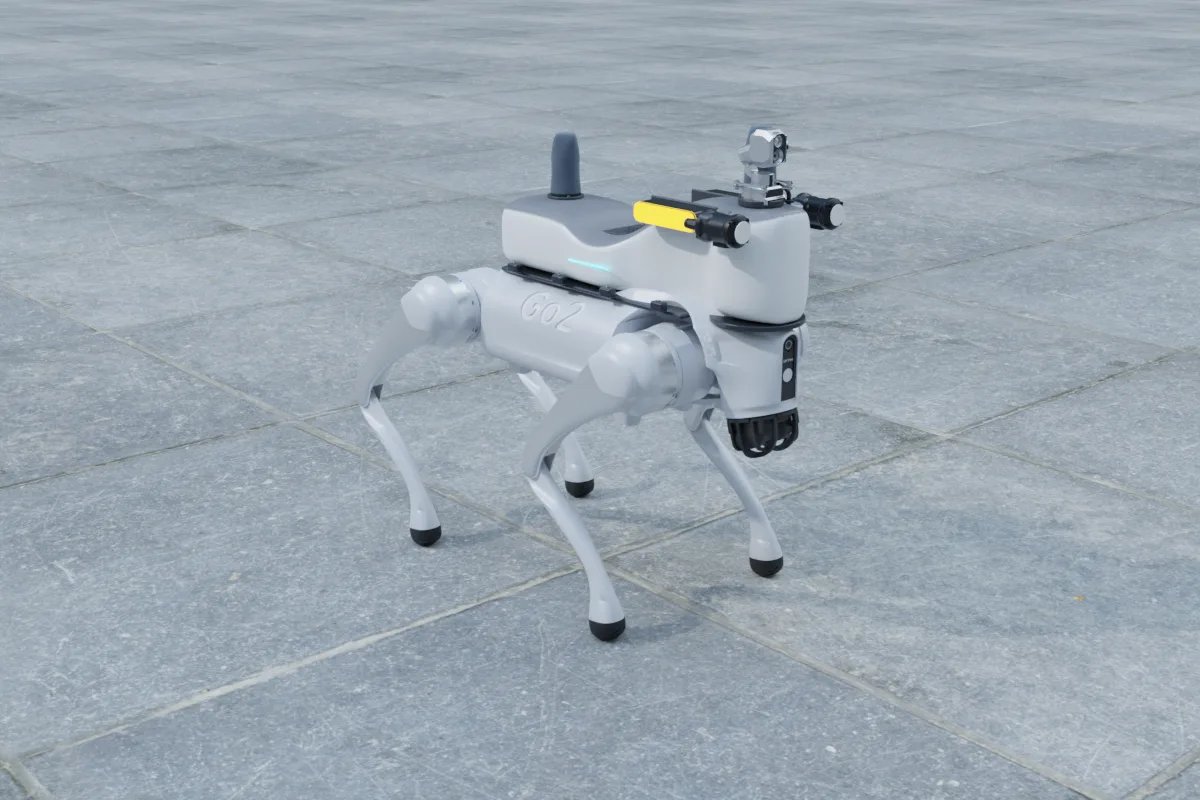
How each sensor talks to the computer
A common Go2 EDU inspection payload contains five devices. None of them needs a proprietary computer; each needs a physical link and a driver.
| Device | Link to computer | ROS 2 side | Weight / power (maker data) |
|---|---|---|---|
| Livox Mid-360 LiDAR | Gigabit Ethernet | Livox ROS Driver 2 (PointCloud2 + IMU) | 265 g / 6.5 W |
| Hikvision HM-TD5737T-4/W dual-spectrum gimbal | Ethernet | RTSP video into an image node; pan/tilt and temperature over the maker's HTTP/ISAPI interface | 2.0 kg / 20 W |
| Intel RealSense D435i | USB 3 | realsense-ros wrapper | 75 g / 2.5 W |
| RTK receiver with two Harxon HX-CH7609A antennas | Serial or USB | NMEA driver publishing NavSatFix and heading | antennas about 30 g each |
| Quectel RM520N-GL 5G module | USB or M.2 | appears as a normal Linux network interface | small; size the supply for transmit peaks |
Because two devices use Ethernet, the payload normally includes a small gigabit switch. If your Jetson carrier board has a single Ethernet port that already connects to the Go2, the switch is what lets the robot, the LiDAR and the gimbal share it.
Check 1: free ports on your carrier board
Count what you already use. The D435i should sit on a USB 3 port, not a hub shared with other high-bandwidth devices. The RTK receiver and the 5G module each take a USB port or, for the modem, an M.2 Key B slot if your carrier board has one. If ports are short, a powered USB 3 hub is fine for the RTK receiver but not ideal for the depth camera.
Check 2: the power budget
Using the maker figures above, the sensors alone draw about 29 W before the 5G module and the switch, and a Jetson Orin NX 16GB is rated for up to 40 W. Your existing Jetson is already powered, so the payload adds roughly the sensor share. Size the DC-DC converters for peaks, not averages: the gimbal motors and the 5G transmitter both spike. Ask whoever builds the payload which rail it draws from on the Go2 and what happens when the robot battery gets low.
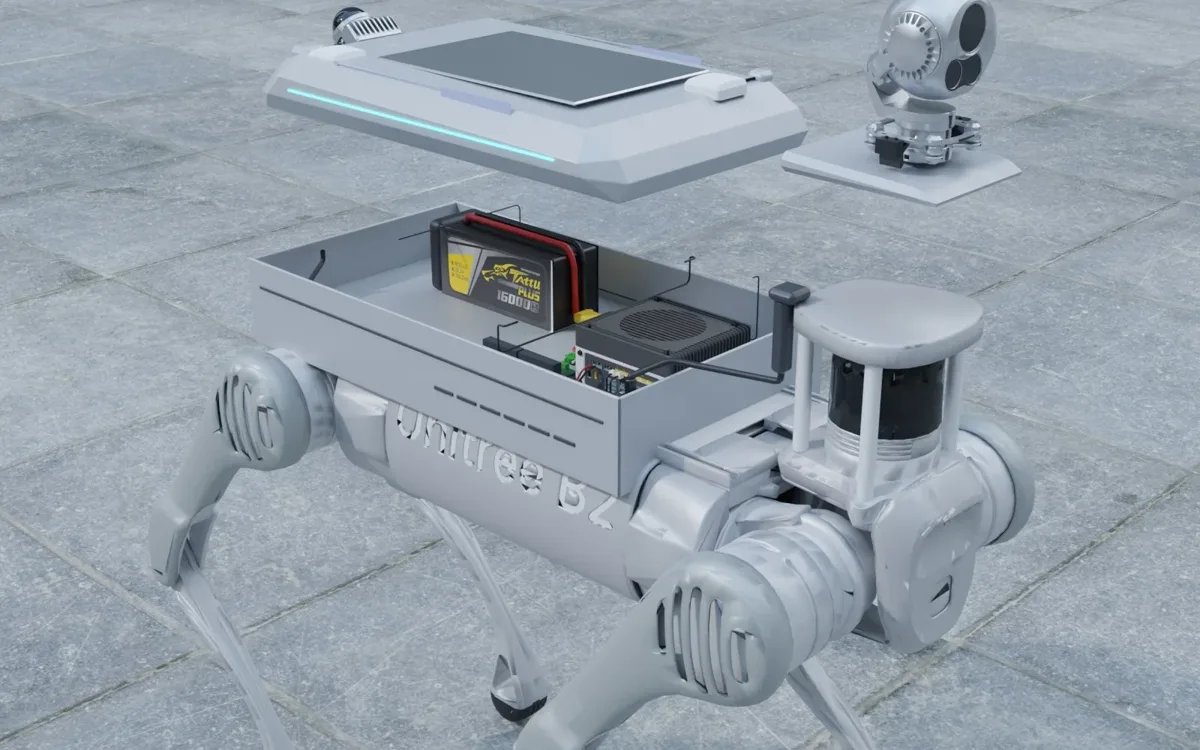
Check 3: IP addresses
This is the most common surprise. The Go2 internal network uses the 192.168.123.x subnet. A Livox Mid-360 ships with an address on 192.168.1.x and sends data to a fixed host address, and IP cameras ship with their own defaults. Decide on one plan before installation: either give the LiDAR and gimbal a separate Ethernet interface and subnet, or move them into a free range of the robot subnet with Livox Viewer and the camera's web page, then update the driver configuration files. Write the final address table into the delivery documents.
Check 4: spare compute
The Orin NX 16GB module is rated at up to 157 TOPS (sparse INT8), which is comfortable for a LiDAR-inertial mapping or localization stack, a ROS 2 navigation planner and one or two camera detection models. The question is what your own software already uses. Run your normal mission, watch CPU, GPU and memory with tegrastats for a few minutes, and keep at least a third free for the payload drivers and point-cloud processing. If you are on an Orin Nano 8GB (67 TOPS in the latest JetPack power mode), keep the workload lighter or offload detection.
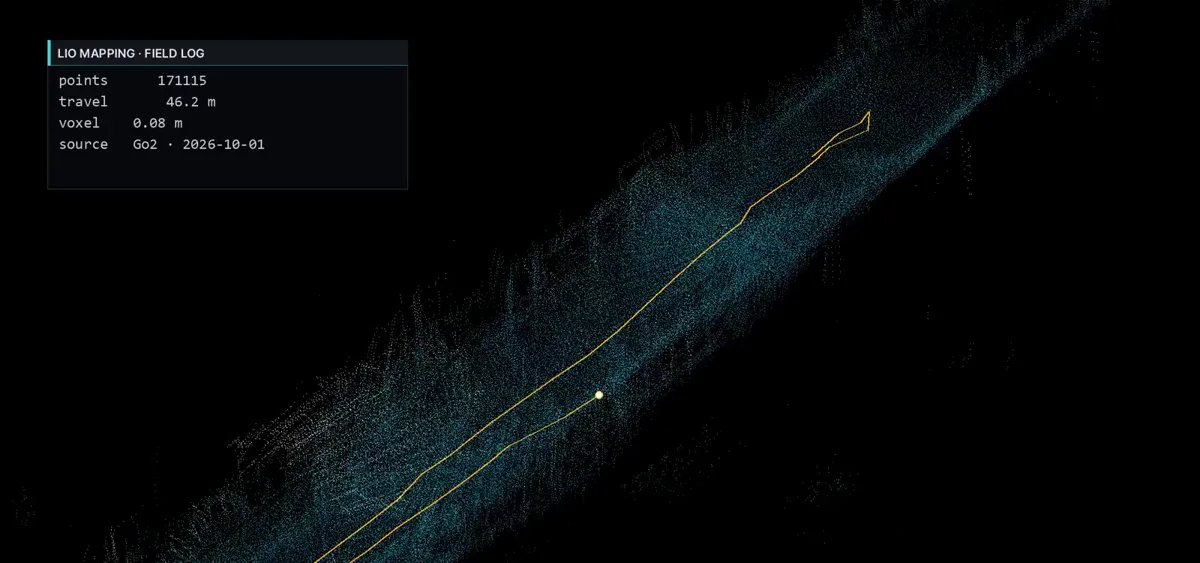
Ubuntu and ROS 2 versions
JetPack 5 is based on Ubuntu 20.04 and JetPack 6 on Ubuntu 22.04. ROS 2 Humble is the usual target on 22.04; on 20.04 many teams still run Foxy or build Humble from source. Livox ROS Driver 2 and the RealSense wrapper support both, so the payload does not force an operating-system upgrade, but tell the integrator your exact JetPack and ROS 2 versions so drivers are built and tested against the same stack.
When a second computer still makes sense
- Your own AI workload already uses most of the Jetson.
- You want the payload software isolated so a driver crash cannot affect your mission software.
- You plan several cameras with continuous detection, which quickly fills one module.
- Different teams own the robot software and the payload software and want to update them independently.
What to send an integrator
Your carrier board model and free ports, JetPack and ROS 2 versions, the current network address plan, a tegrastats log from a normal run, and the list of sensors you need. With that, a payload can be designed around your computer instead of adding one by default. Our related guides cover choosing a LiDAR for the Go2 EDU and adding a thermal camera.
Next steps
Build your sensor list with live weight and power totals in the online payload configurator and send it for a quote, or see the kit page for the Unitree Go2 EDU inspection payload kit (from US$8,990 without onboard computer). Platform details: Unitree Go2 EDU and Unitree B2. Services: robot payload integration, quadruped development and robot autonomy software.
FAQ
Do I need a separate computer for a Unitree Go2 EDU payload?
Not always. If the robot already carries a Jetson Orin NX 16GB running Ubuntu and ROS 2, a LiDAR, a dual-spectrum gimbal, a depth camera, an RTK receiver and a 5G module can normally connect to it directly over Ethernet, USB and serial. A second computer is worth it when your own AI workload already uses most of the Jetson or when you want the payload isolated from your software.
Which ROS 2 drivers does a typical robot dog payload use?
Livox ROS Driver 2 for a Livox Mid-360 LiDAR, the Intel RealSense ROS 2 wrapper for a D435i, an RTSP video stream plus the manufacturer's HTTP/ISAPI interface for a Hikvision gimbal, an NMEA serial driver for the RTK receiver, and the standard Linux network interface for a Quectel 5G module.
Will a Livox Mid-360 conflict with the Unitree Go2 network?
It can. The Go2 internal network uses the 192.168.123.x subnet, while a Mid-360 ships on 192.168.1.x and expects the host on a fixed address. Either give the LiDAR its own Ethernet port and subnet, or change its IP with Livox Viewer and update the driver configuration.
Is a Jetson Orin NX 16GB powerful enough for mapping and detection on a robot dog?
For one LiDAR-inertial mapping or localization stack, a navigation planner and one or two camera detection models it usually is: the module is rated at up to 157 TOPS (sparse INT8) and up to 40 W. Measure your existing load first; if it is already high, add a second module instead of fighting for headroom.
What is the price of a Go2 EDU payload kit without an onboard computer?
Our Unitree Go2 EDU inspection payload kit starts from US$8,990 ex-works without the onboard computer; adding a Jetson Orin NX costs US$2,290. Shipping and import duty are quoted per destination.