Solutions › UGV payload and autonomy integration
UGV payload and autonomy integration
UGV chassis carry more and have room for multiple sensors and serious compute. We build the sensor frame, harness and power, then install the navigation and task software.
What we do
- Sensor frames and covers: multi-beam LiDAR, 4D radar, depth cameras, dual-antenna RTK heading
- Power and networking: DC-DC, UPS, PoE, rugged switches, time sync
- Autonomy: mapping, localization, path planning, obstacle avoidance, outdoor RTK fusion
- Implements: quick-swap mower, snow and leaf modules (parametric CAD and simulation)
Platforms
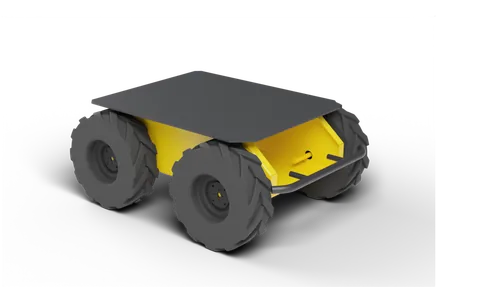
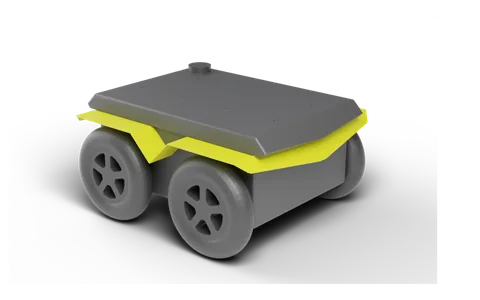
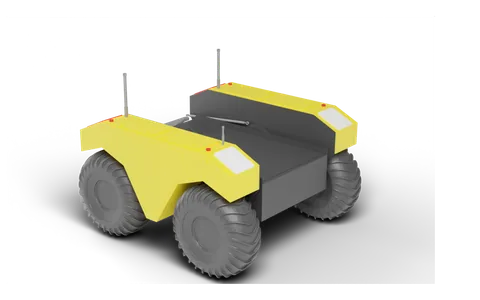
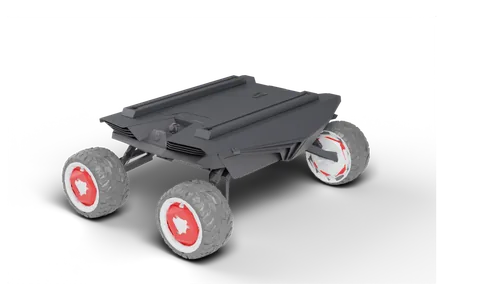
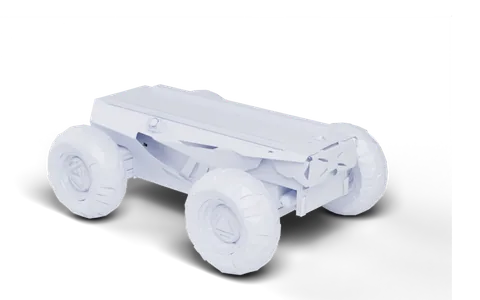
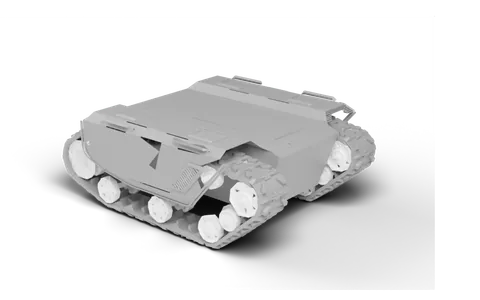
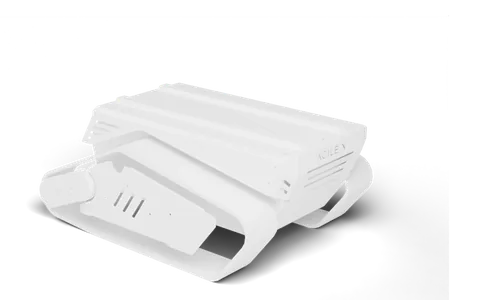
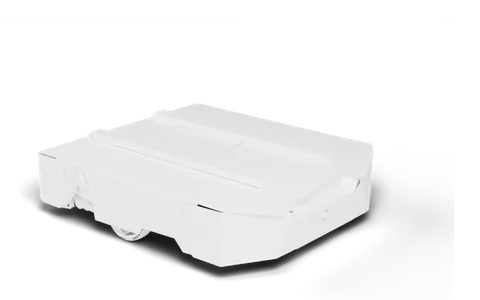
Related projects
- Quadruped / UGV / drone sensor payload design: Per OEM models and official colors, we design integrated sensor payloads for B2 quadrupeds, Husky UGVs, M350 drones and more: enclosures hug the body, balanced for center of gravity, batteries and cables routed inside, with exploded views and renders.
- Agricultural multi-function robot · Parametric modeling and MuJoCo simulation: One chassis with quick-swap front modules for mowing, snow clearing and leaf collection, fully modeled in CadQuery (hundreds of parts, with exploded assembly views), and simulated in MuJoCo for full-coverage mowing, obstacle avoidance, self-recovery, module swapping and auto-docking.
FAQ
- How is a UGV payload different from a robot dog payload?
- UGVs carry heavier LiDAR and bigger compute; robot dogs need tight weight control and leg clearance but handle rougher terrain.
Tell us about your project
Send the platform, the sensors you need and the use case. We reply with a payload design, weight and power budget, and a quote.
Sales: Li Zhongpan · +86 186 0689 5919 (WeChat) · lizhongpan@yuanzhirobot.com
Engineering: Mo Yuncong · +86 192 6342 5759 · 2211955800@qq.com
Address: Room B602, Hetu Park, No. 500 Shunqing Road, Songjiang, Shanghai 201615, China